Map observations
Convert each robot’s camera and state inputs into the policy’s expected observation format.
 FIELDrun
02 / POLICY-TO-ROBOT ADAPTATION
FieldAdapt maps each robot’s sensors, state representation, coordinate frames, and control interface to the policy’s expected inputs and outputs.
Talk to us about FieldAdapt ↗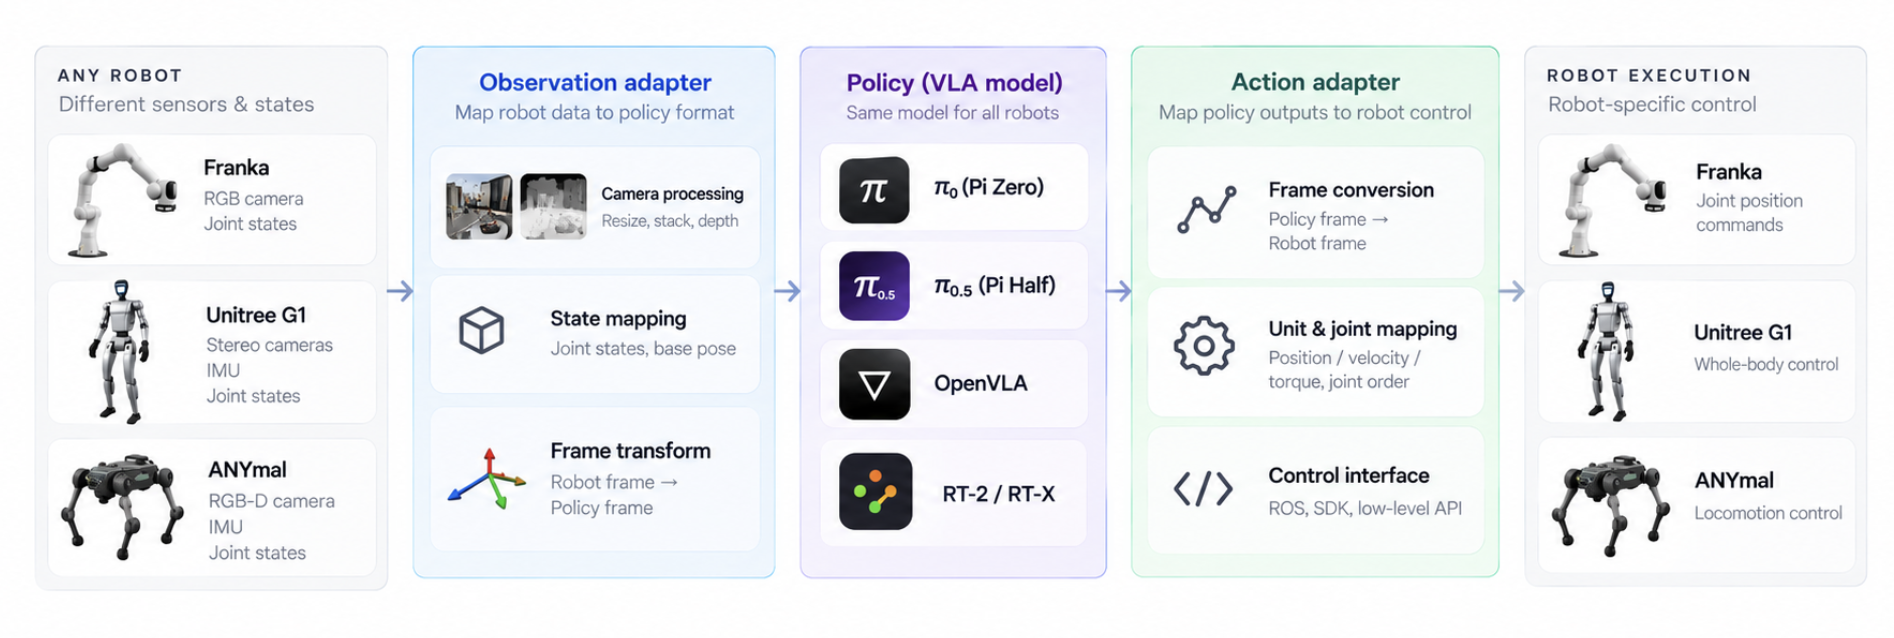
Convert each robot’s camera and state inputs into the policy’s expected observation format.
Map policy outputs to robot-specific frames, joint conventions, units, and control APIs.
Check interface behavior and task execution on the target robot and control loop.